Visin Fusion
A Python library for comparing camera and projected LiDAR semantic segmentation models. Import a model into your own code, or use the optional pipeline to train, evaluate, visualize and benchmark it from a config.
from visin_fusion.models import CLFTv2

model = CLFTv2(num_classes=4, mode="cross_fusion")
logits = model(rgb, lidar)  # [batch, classes, height, width]
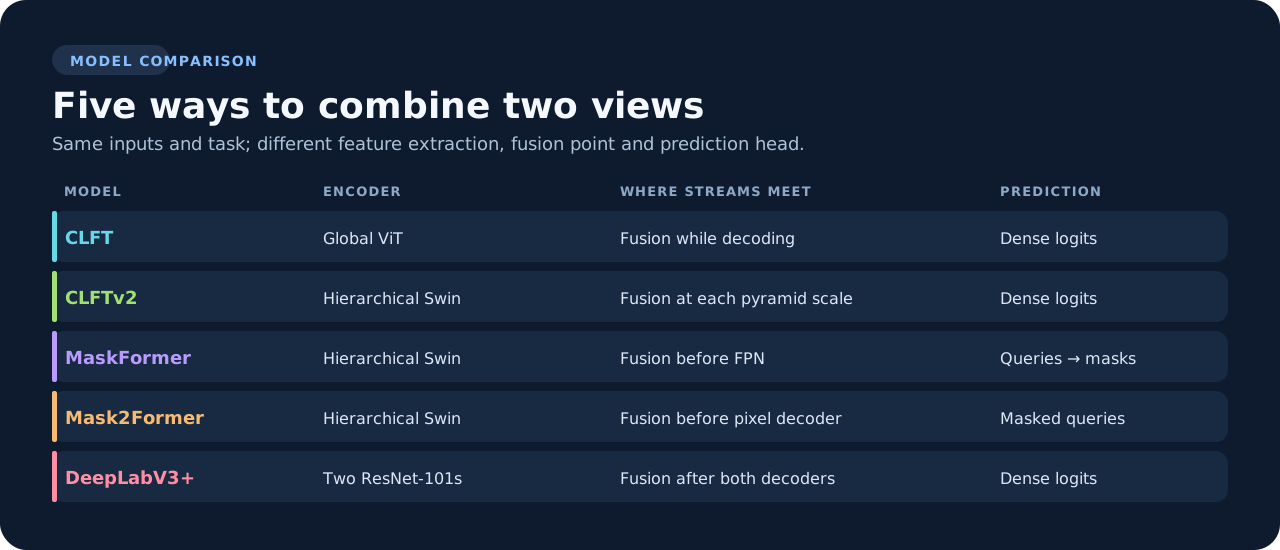
Five research model families share this calling convention. Their fusion points and prediction heads differ:
Where to start
| I want to... | Go to |
|---|---|
| Try it in five minutes | Getting started |
| Train on my own data | Getting started, then Configs |
| Train on ZOD, Waymo or iseAuto | Download and train |
| Call a model from my own code | Use as a library |
| Fix an error | Troubleshooting |
All pages
- Use as a library: installation, model API, inference, training and checkpoints.
- Compare models: diagrams, implementation differences and paper references.
- Getting started: install, run the sample, and train on your own data, on one page.
- Download and train: ZOD, Waymo, and Iseauto examples for all four CLI stages.
- Training examples: choose among five models and RGB, LiDAR, or fusion.
- Configs and Datasets: run the pipeline on your own data.
One install covers the models and the full pipeline. Visin reporting and visin: datasets use the optional visin extra.